Research Updates
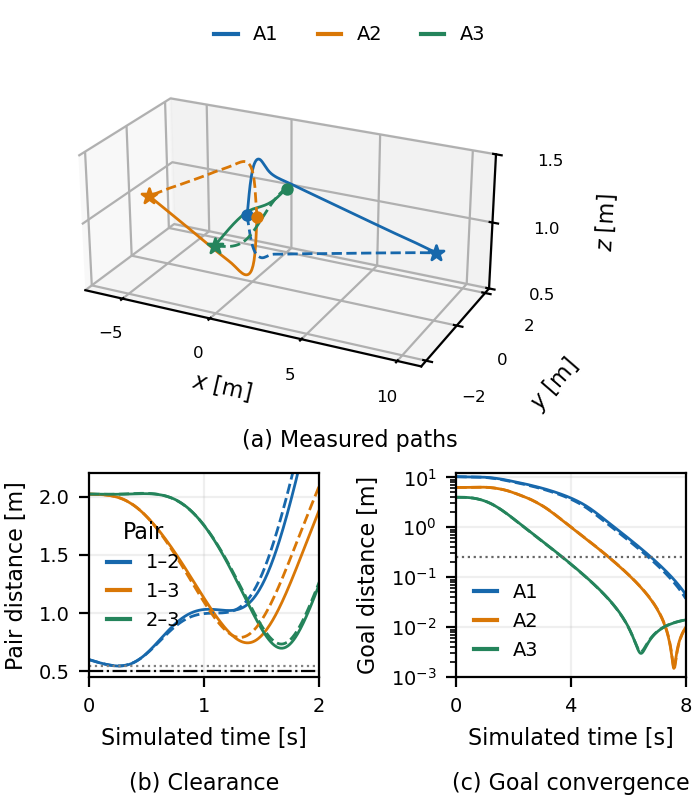
- Nov 2026: New preprint with Miroslav Flídr on game-theoretic MPC for drone coordination. Paper · Code.
- 2025: Expanded the UAV laboratory with two Crazyflie Brushless drones and a Raspberry Pi 5 with an AI HAT to support experimental research on agile flight and onboard AI.
- Jan 2025: Joined NTIS, University of West Bohemia, as a postdoctoral researcher in the Identification and Decision Making group.
- Dec 2024: Presented work on Lazy Theta* initialization for UAV trajectory optimization at ICARCV 2024 in Dubai.
- Nov 2024: Defended my Ph.D. thesis, Trajectory Planning and Tracking for Unmanned Aerial Vehicles.
Research Focus
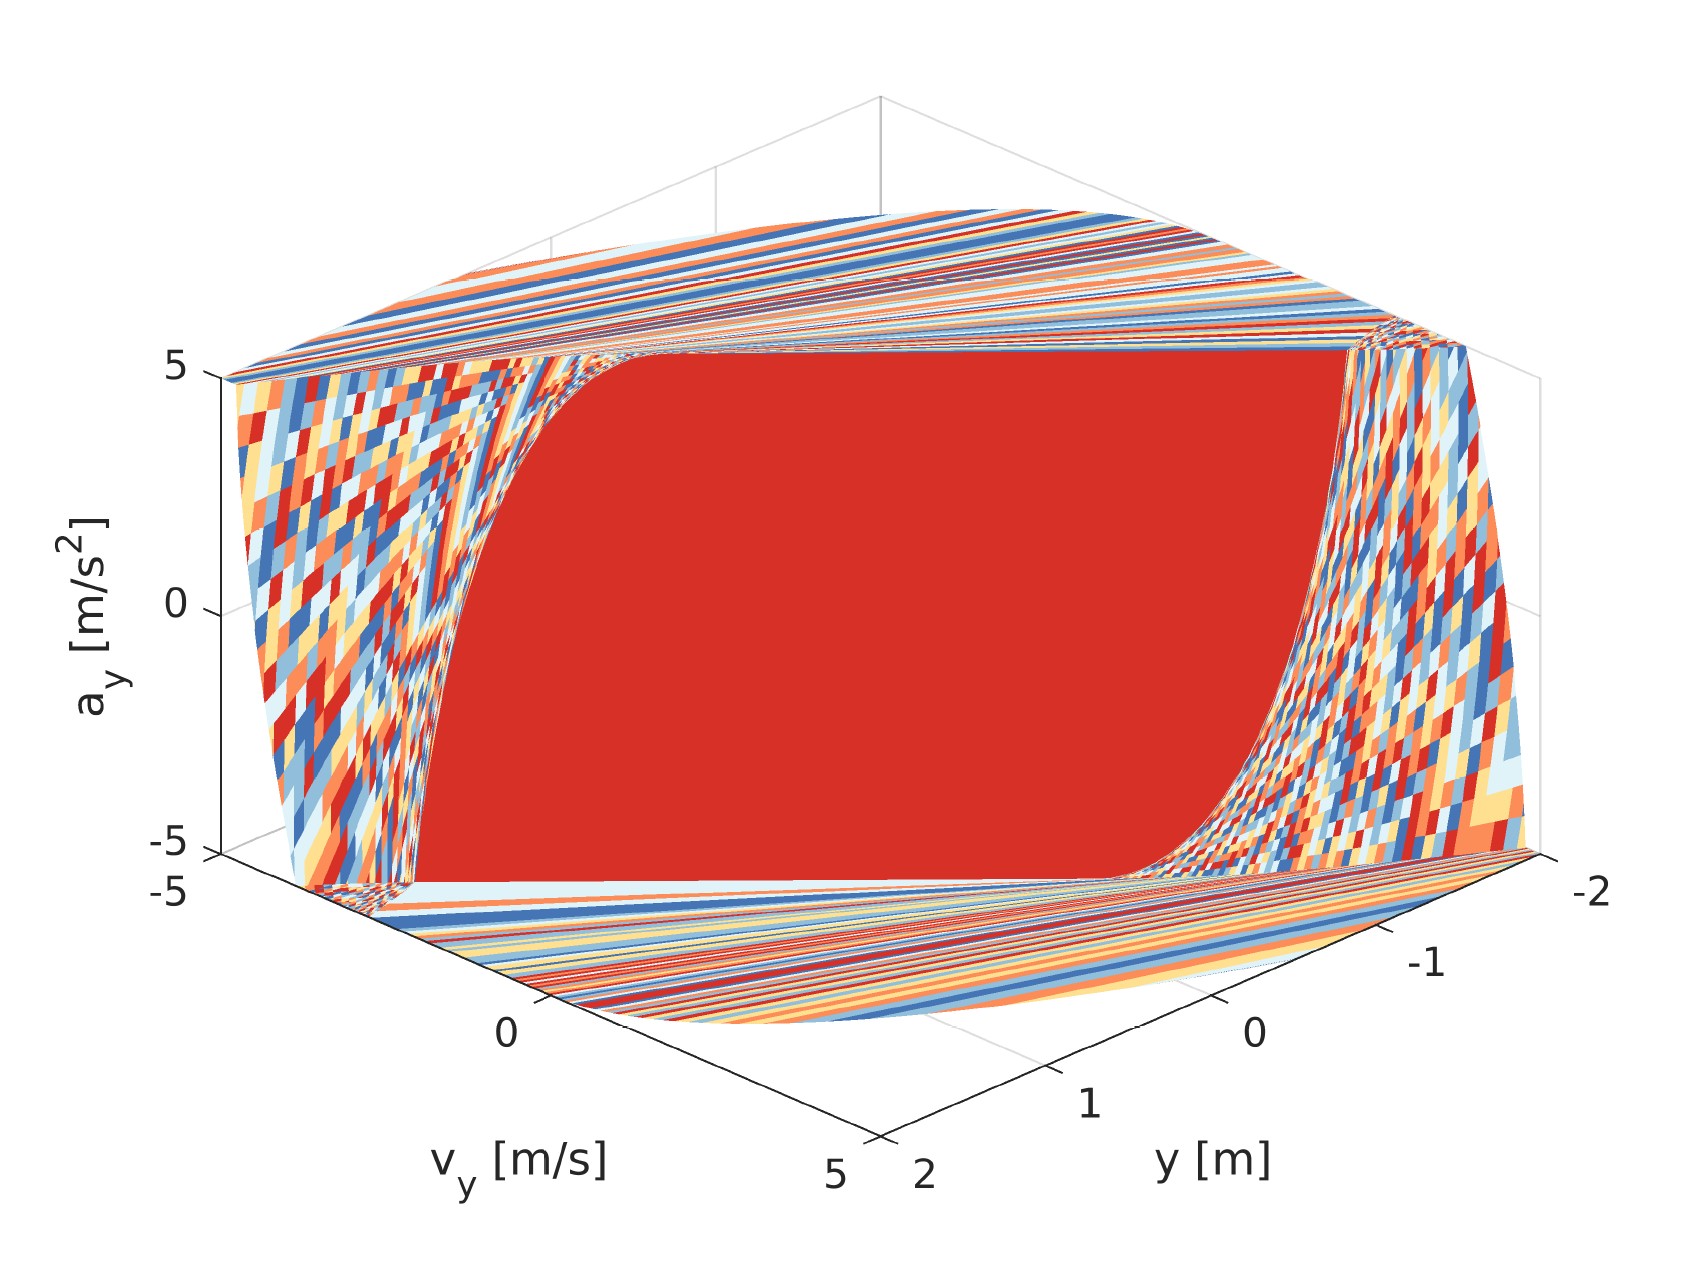
Interpolating and Model Predictive Control
Developing robust control algorithms for agile UAV flight in constrained environments.
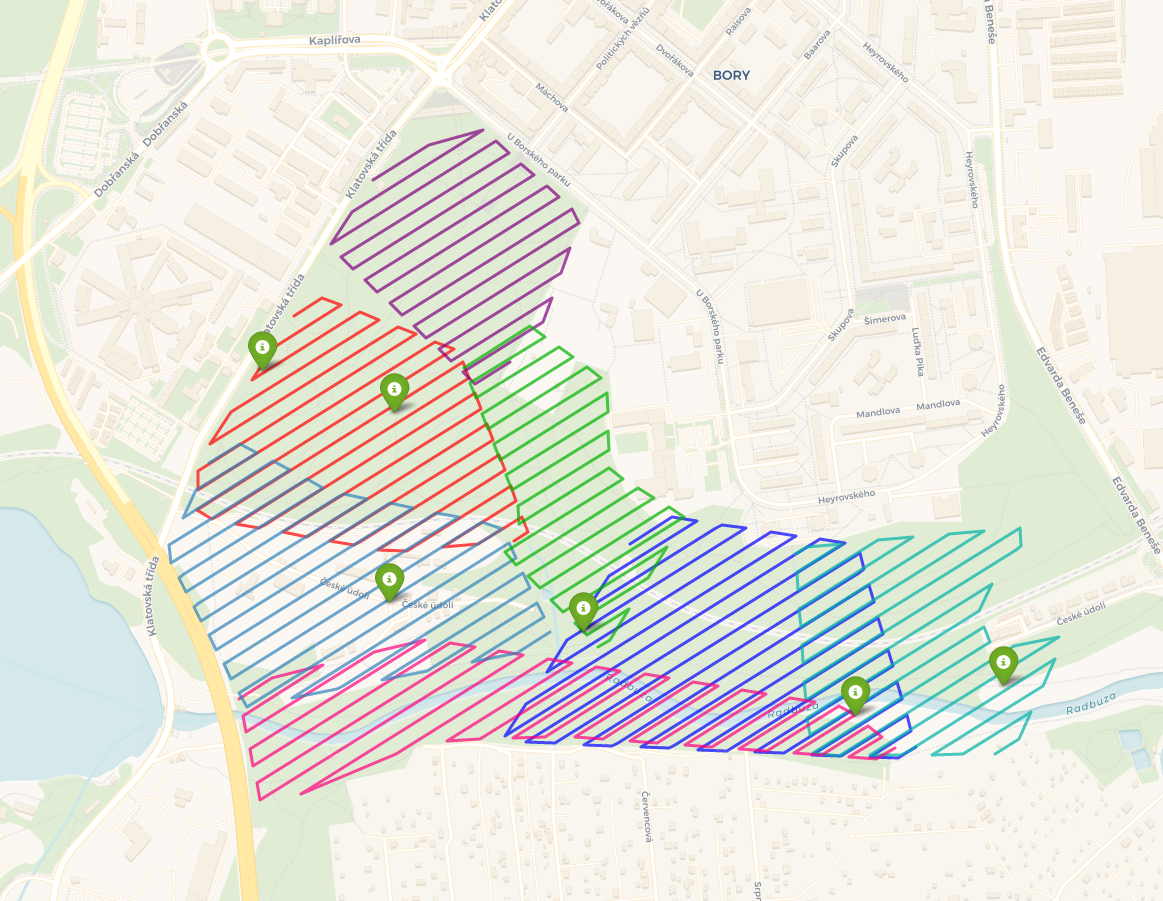
Trajectory Planning
Real-time generation of optimal, collision-free paths for complex missions.
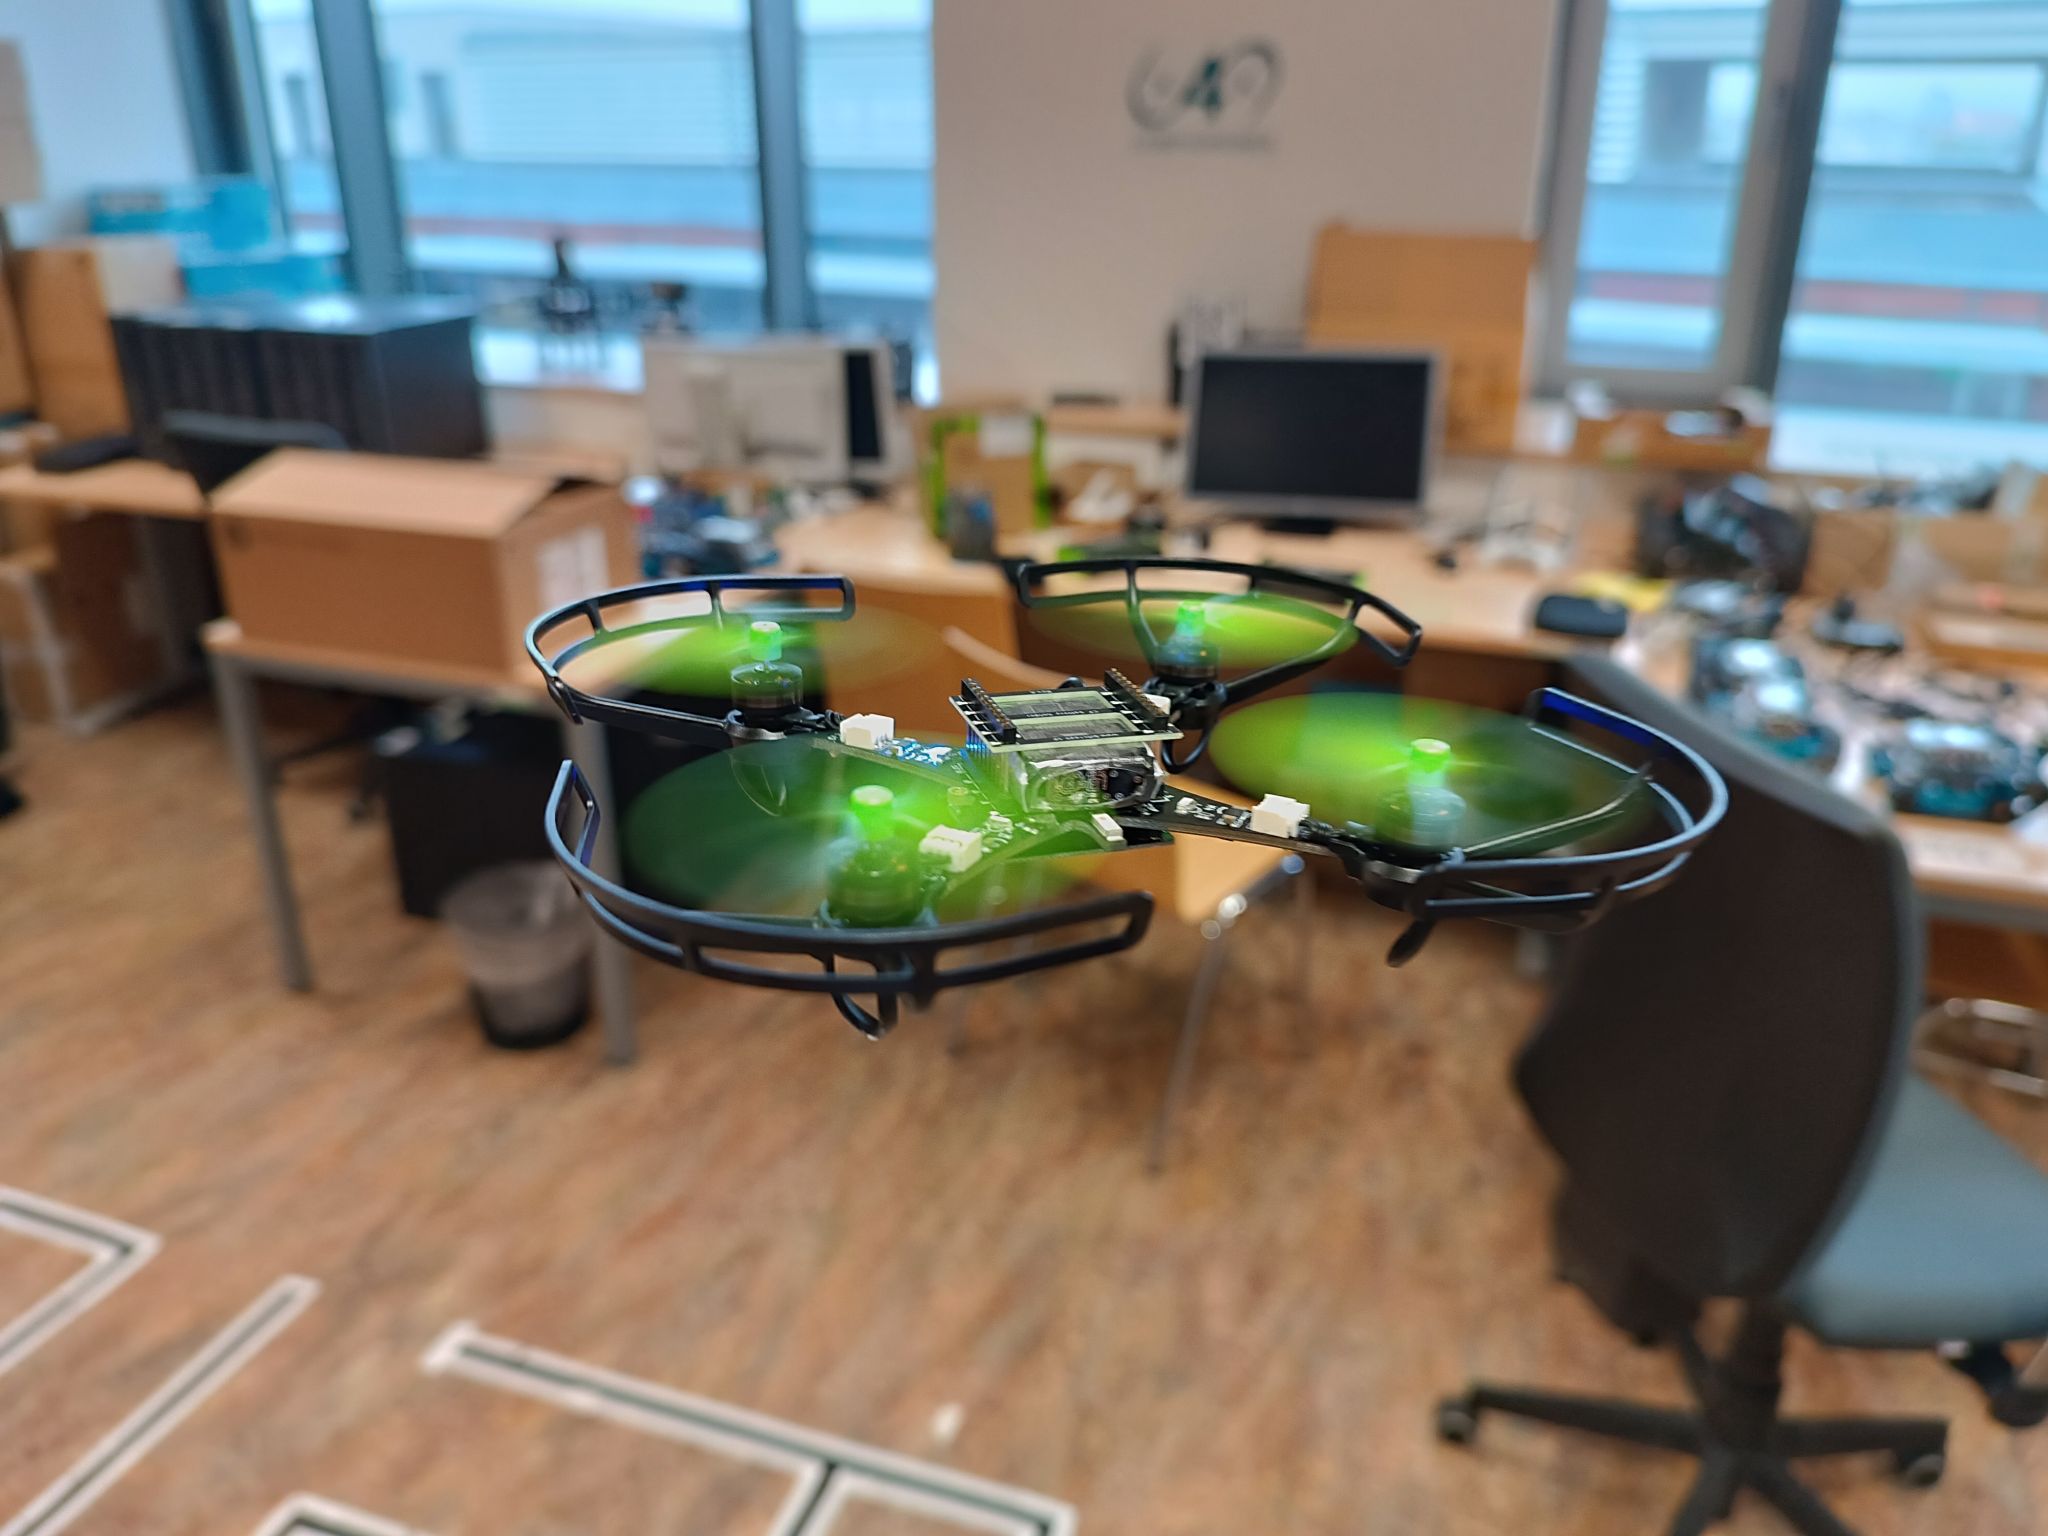
Aerial Robotics
Full-stack implementation on PX4 and Crazyflie platforms, from theory to flight.
About Me
I’m a postdoctoral researcher in the Identification and Decision Making group at NTIS, University of West Bohemia in Pilsen. I work on control and trajectory planning for autonomous UAVs, with a focus on computationally efficient interpolating control and optimization-based planning. I am also exploring game-theoretic MPC for multi-UAV coordination.
I develop and test control algorithms in simulation and in flight, using Crazyflie and PX4-based platforms. My research software is mainly written in MATLAB and Python. One of my current goals is to bring interpolating control directly into Crazyflie firmware and evaluate it in flight experiments.
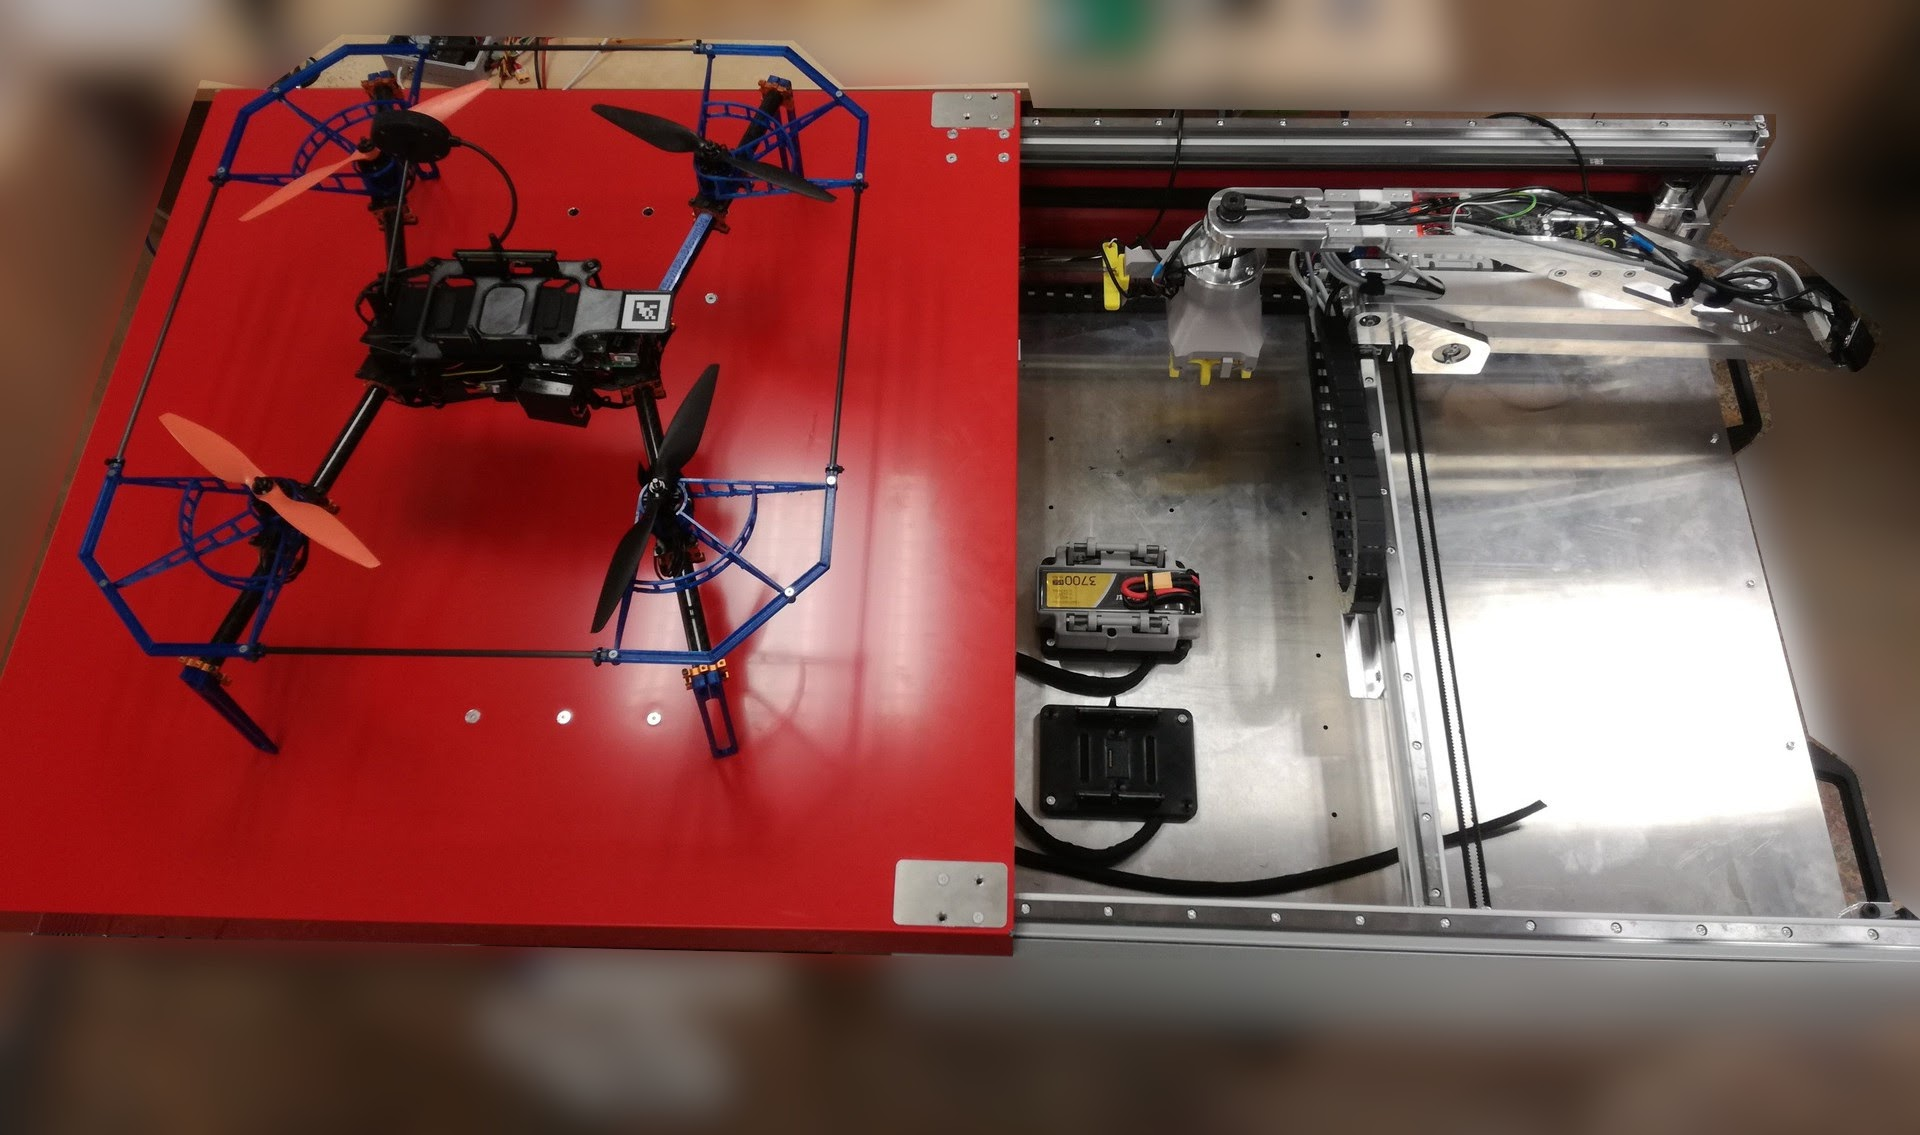
Alongside research, I teach MATLAB programming and supervise theses on UAV control, trajectory tracking, and multi-UAV coordination. In the EU Comp4Drones project, I developed the Drone Commander and Mission Planner modules for Droneport, an autonomous UAV battery-swapping station.
Selected Publications
- Bouček, Z., & Flídr, M. (2026). A Game-Theoretic MPC Planner for Cooperative and Adversarial Drone Coordination. arXiv. (Preprint) [DOI] [arXiv] [Code]
- Bouček, Z., Flídr, M., & Straka, O. (2024). Trajectory Tracking for UAVs: An Interpolating Control Approach. 2024 28th International Conference on Methods and Models in Automation and Robotics (MMAR), 387–392. [DOI] [arXiv]
- Bouček, Z., Flídr, M., & Straka, O. (2024). Leveraging Lazy Theta* Path Planning for UAV Pseudospectral Trajectory Optimization Initialization. 2024 18th International Conference on Control, Automation, Robotics and Vision (ICARCV), 422–427. [DOI] [arXiv]
- Bouček, Z., & Flídr, M. (2024). Mission Planner for UAV Battery Replacement. IEEE International Conference on Multisensor Fusion and Integration for Intelligent Systems. [DOI] [arXiv]
- Severa, O., Bouček, Z., Neduchal, P., Bláha, L., Myslivec, T., & Flídr, M. (2022). Droneport: From Concept To Simulation. System Engineering for Constrained Embedded Systems, 33–38. [DOI]
Projects
Game-Theoretic MPC for Drone Coordination Multi-UAV planning · Game theory
Interpolating Control for UAVs UAV control · Embedded systems
While Model Predictive Control (MPC) offers high performance, it is computationally expensive. This work introduces an Interpolating Control approach that matches MPC’s accuracy in tracking complex trajectories while significantly reducing the processing load. This ensures robust performance even on onboard hardware with limited computing power.
Read Paper PreprintHybrid Trajectory Optimization Planning · Optimal control
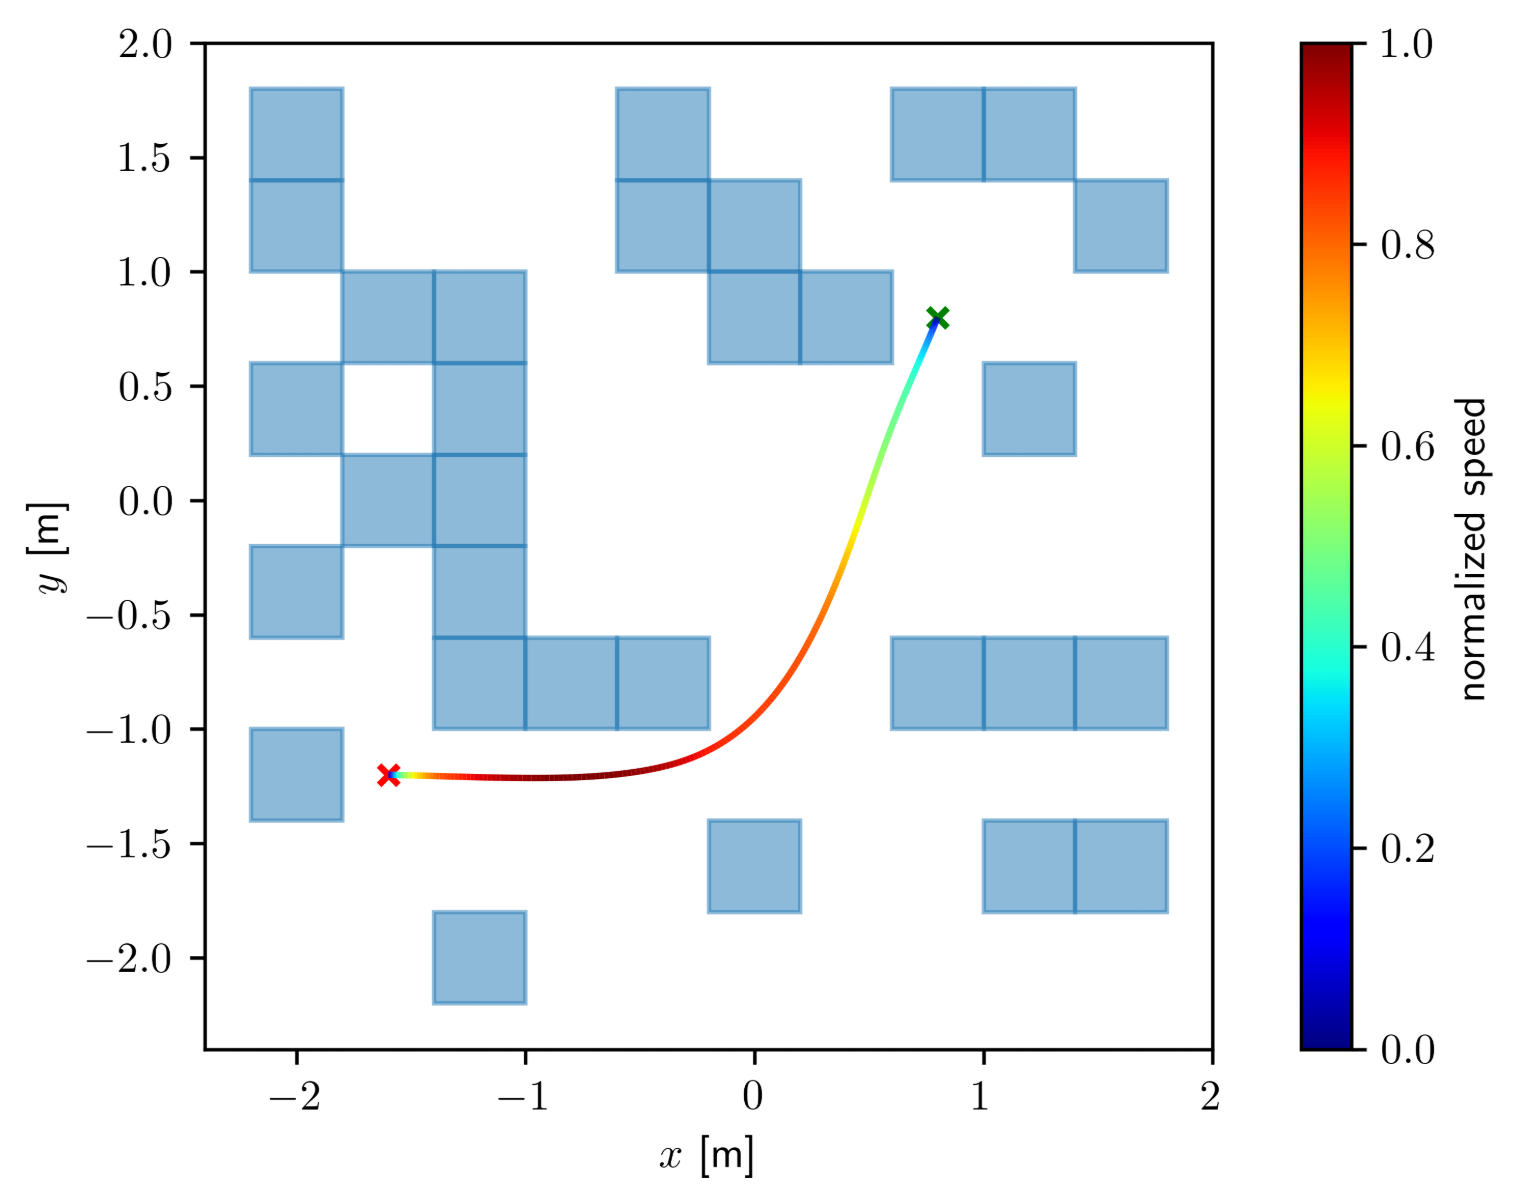
Combines Lazy Theta* path planning with pseudospectral trajectory optimization, using a geometric path to initialize the optimization problem in cluttered environments.
Read Paper GitHub PreprintMission Control for Autonomous Battery Swapping UAV autonomy · Comp4Drones
Curriculum Vitae
Education
- Ph.D. in Cybernetics, University of West Bohemia in Pilsen, 2024
Dissertation: “Trajectory Planning and Tracking for Unmanned Aerial Vehicles” GitHub - Ing. in Automation & Robotics, University of West Bohemia in Pilsen, 2015
Positions
- 2025–present — Postdoctoral Researcher, NTIS, UWB (IDM group)
- 2015–2024 — Ph.D. Researcher, NTIS, UWB
Teaching & Mentoring
- 2024–present — University course in MATLAB programming syllabus
- 2015–present — Tutor, Campo Arduino & Campo Lampone summer programs
Supervision of Student Theses
- Frei, O. (2025). Drone Optimal Control [Bachelor’s Thesis, University of West Bohemia].
- Herman, J. (2024). Leader Follower Task with Drones [Bachelor’s Thesis, University of West Bohemia].
- Kozel, L. (2024). Suspended Load Transport By Drone [Bachelor’s Thesis, University of West Bohemia].
- Vrba, J. (2023). Drone trajectory tracking [Bachelor’s Thesis, University of West Bohemia].
- Benda, O. (2022). Drone Swarm Control [Bachelor’s Thesis, University of West Bohemia].
Specialized Training
- Reinforcement Learning Onramp (2026) - MATLAB Academy self-paced training (certificate PDF)
- IEEE RAS Summer School on Multi‑Robot Systems (2020, 2022) – practical multi‑UAV tasks
- Self‑Driving Cars with Duckietown (2021) – MOOC on autonomy algorithms
- E‑Knot Multi‑Sensors Navigation Course (2017) – GNSS, INS, and SLAM techniques
Contact
Academic: zboucek@fav.zcu.cz
Consulting: zboucek@gmail.com